Robot Path Planning Based on Visual SLAM

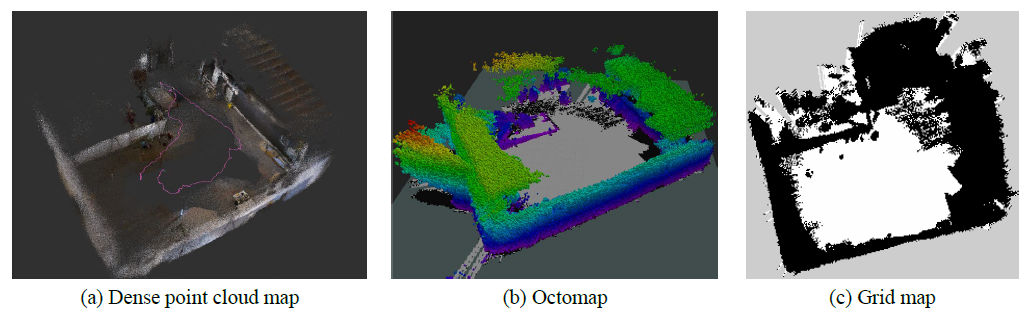
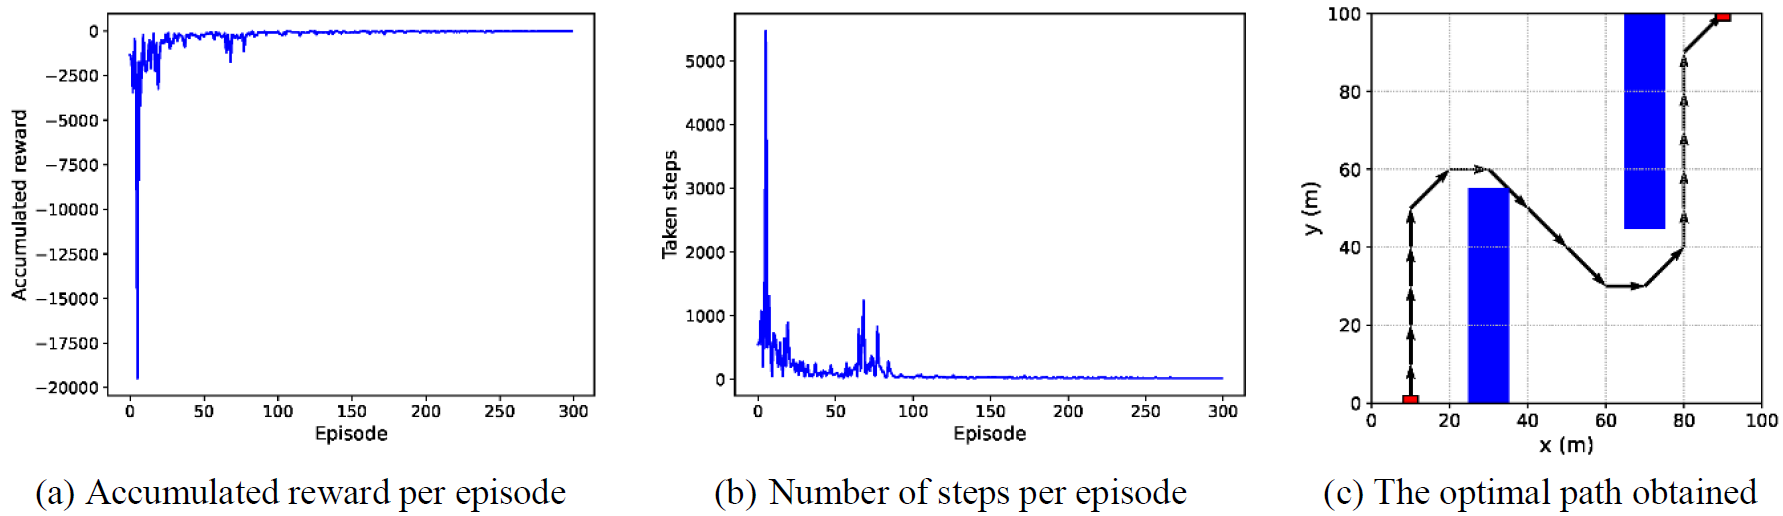
  • Description: This project extends ORB-SLAM3 with dense point-cloud mapping based on RGB-D data, converts dense maps into Octomap and lightweight 2D occupancy grids, and evaluates reinforcement-learning-based planners for autonomous navigation.
  • Role: Independent researcher, algorithm designer, system developer.
  • Keywords: Visual SLAM, robot path planning, dense mapping, occupancy grid mapping, reinforcement learning, autonomous navigation.
Map convertion process form cloud map to grid map
Map convertion process form cloud map to grid map.
Robot path planning based on DQN
Robot path planning based on DQN.