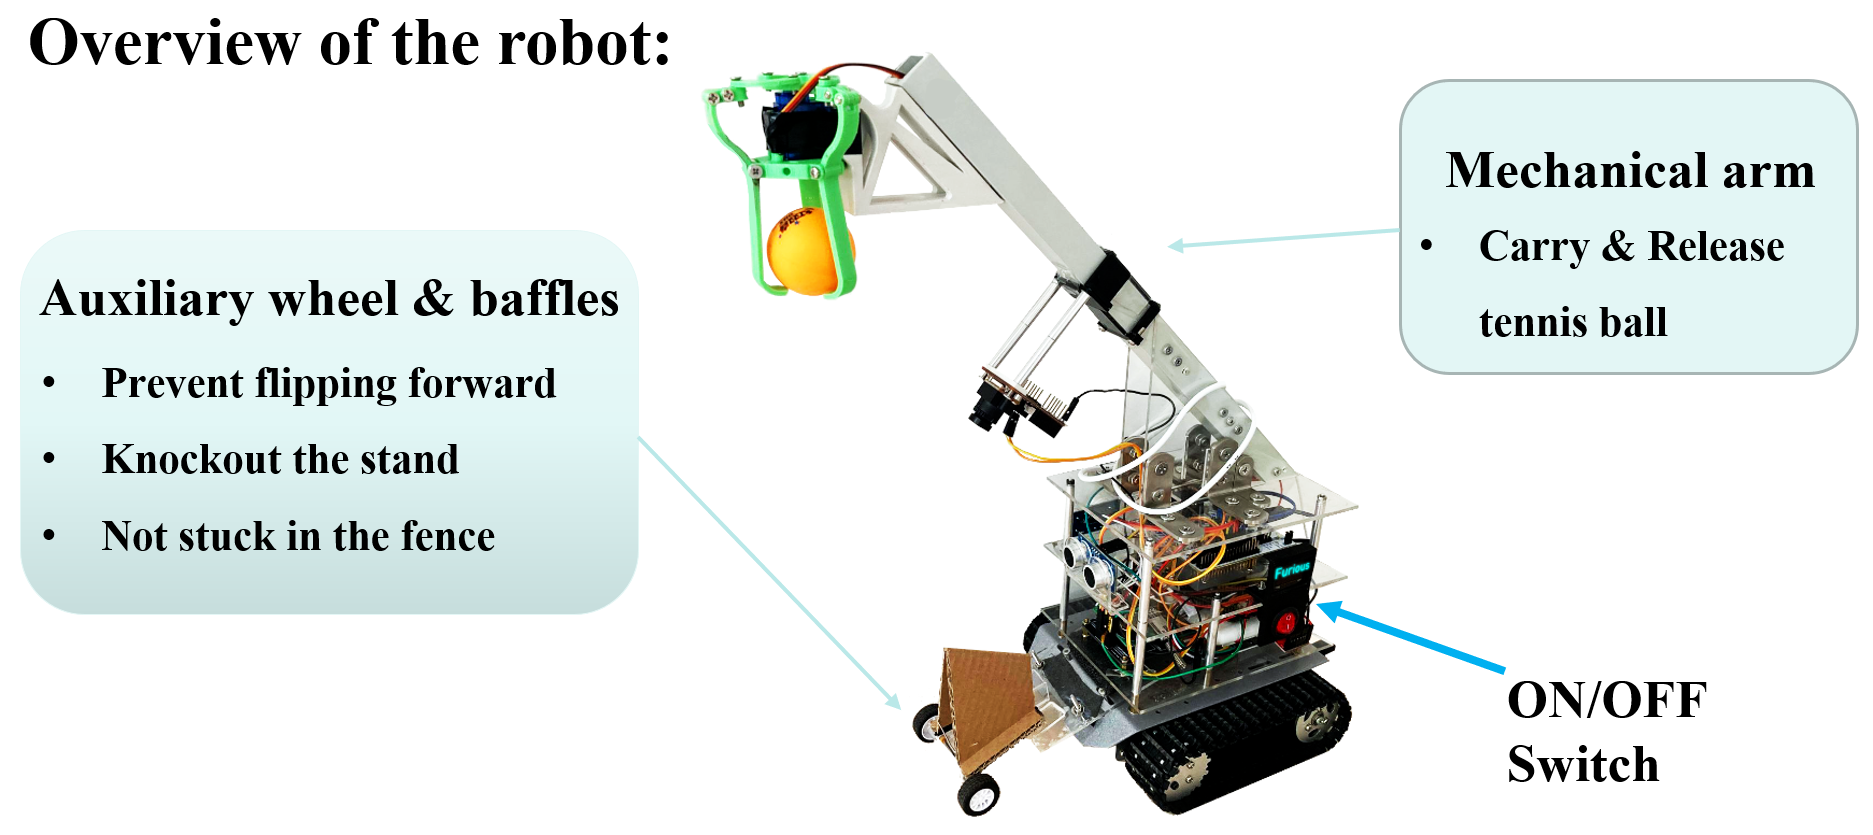
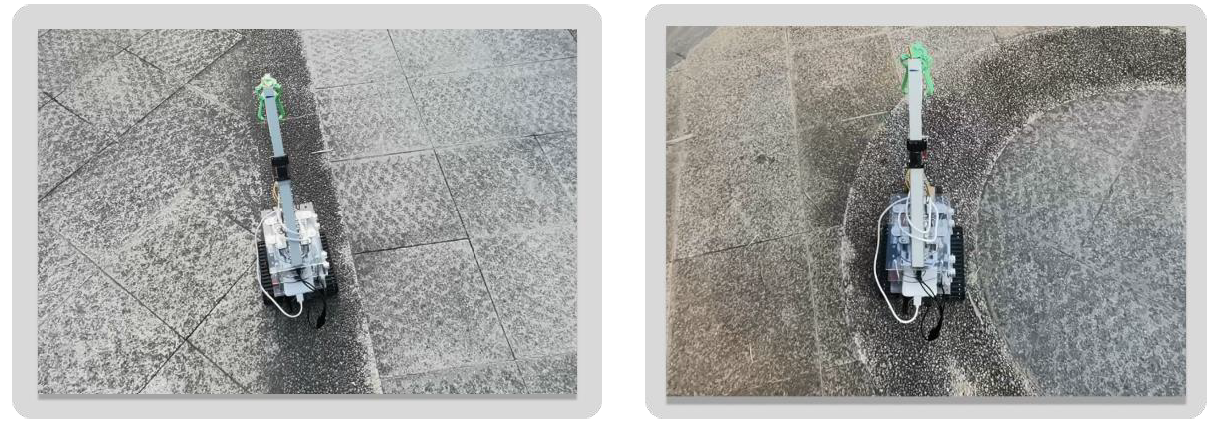
Description: This team design project built an autonomous smart robot car for navigation, recognition and transportation tasks, integrating mechanical chassis construction, motor control, visual perception, ultrasonic sensing, and a mechanical arm/claw. The robot combined an mbed-based control system with OpenMV vision to recognize visual cues, navigate the task field, and execute object-handling actions during field demonstrations.
Role: Team member, responsible for robot car frame construction, PID/control tuning, and field experiments.