Joint Optimization of Multi-UAV Beamforming and Path Planning
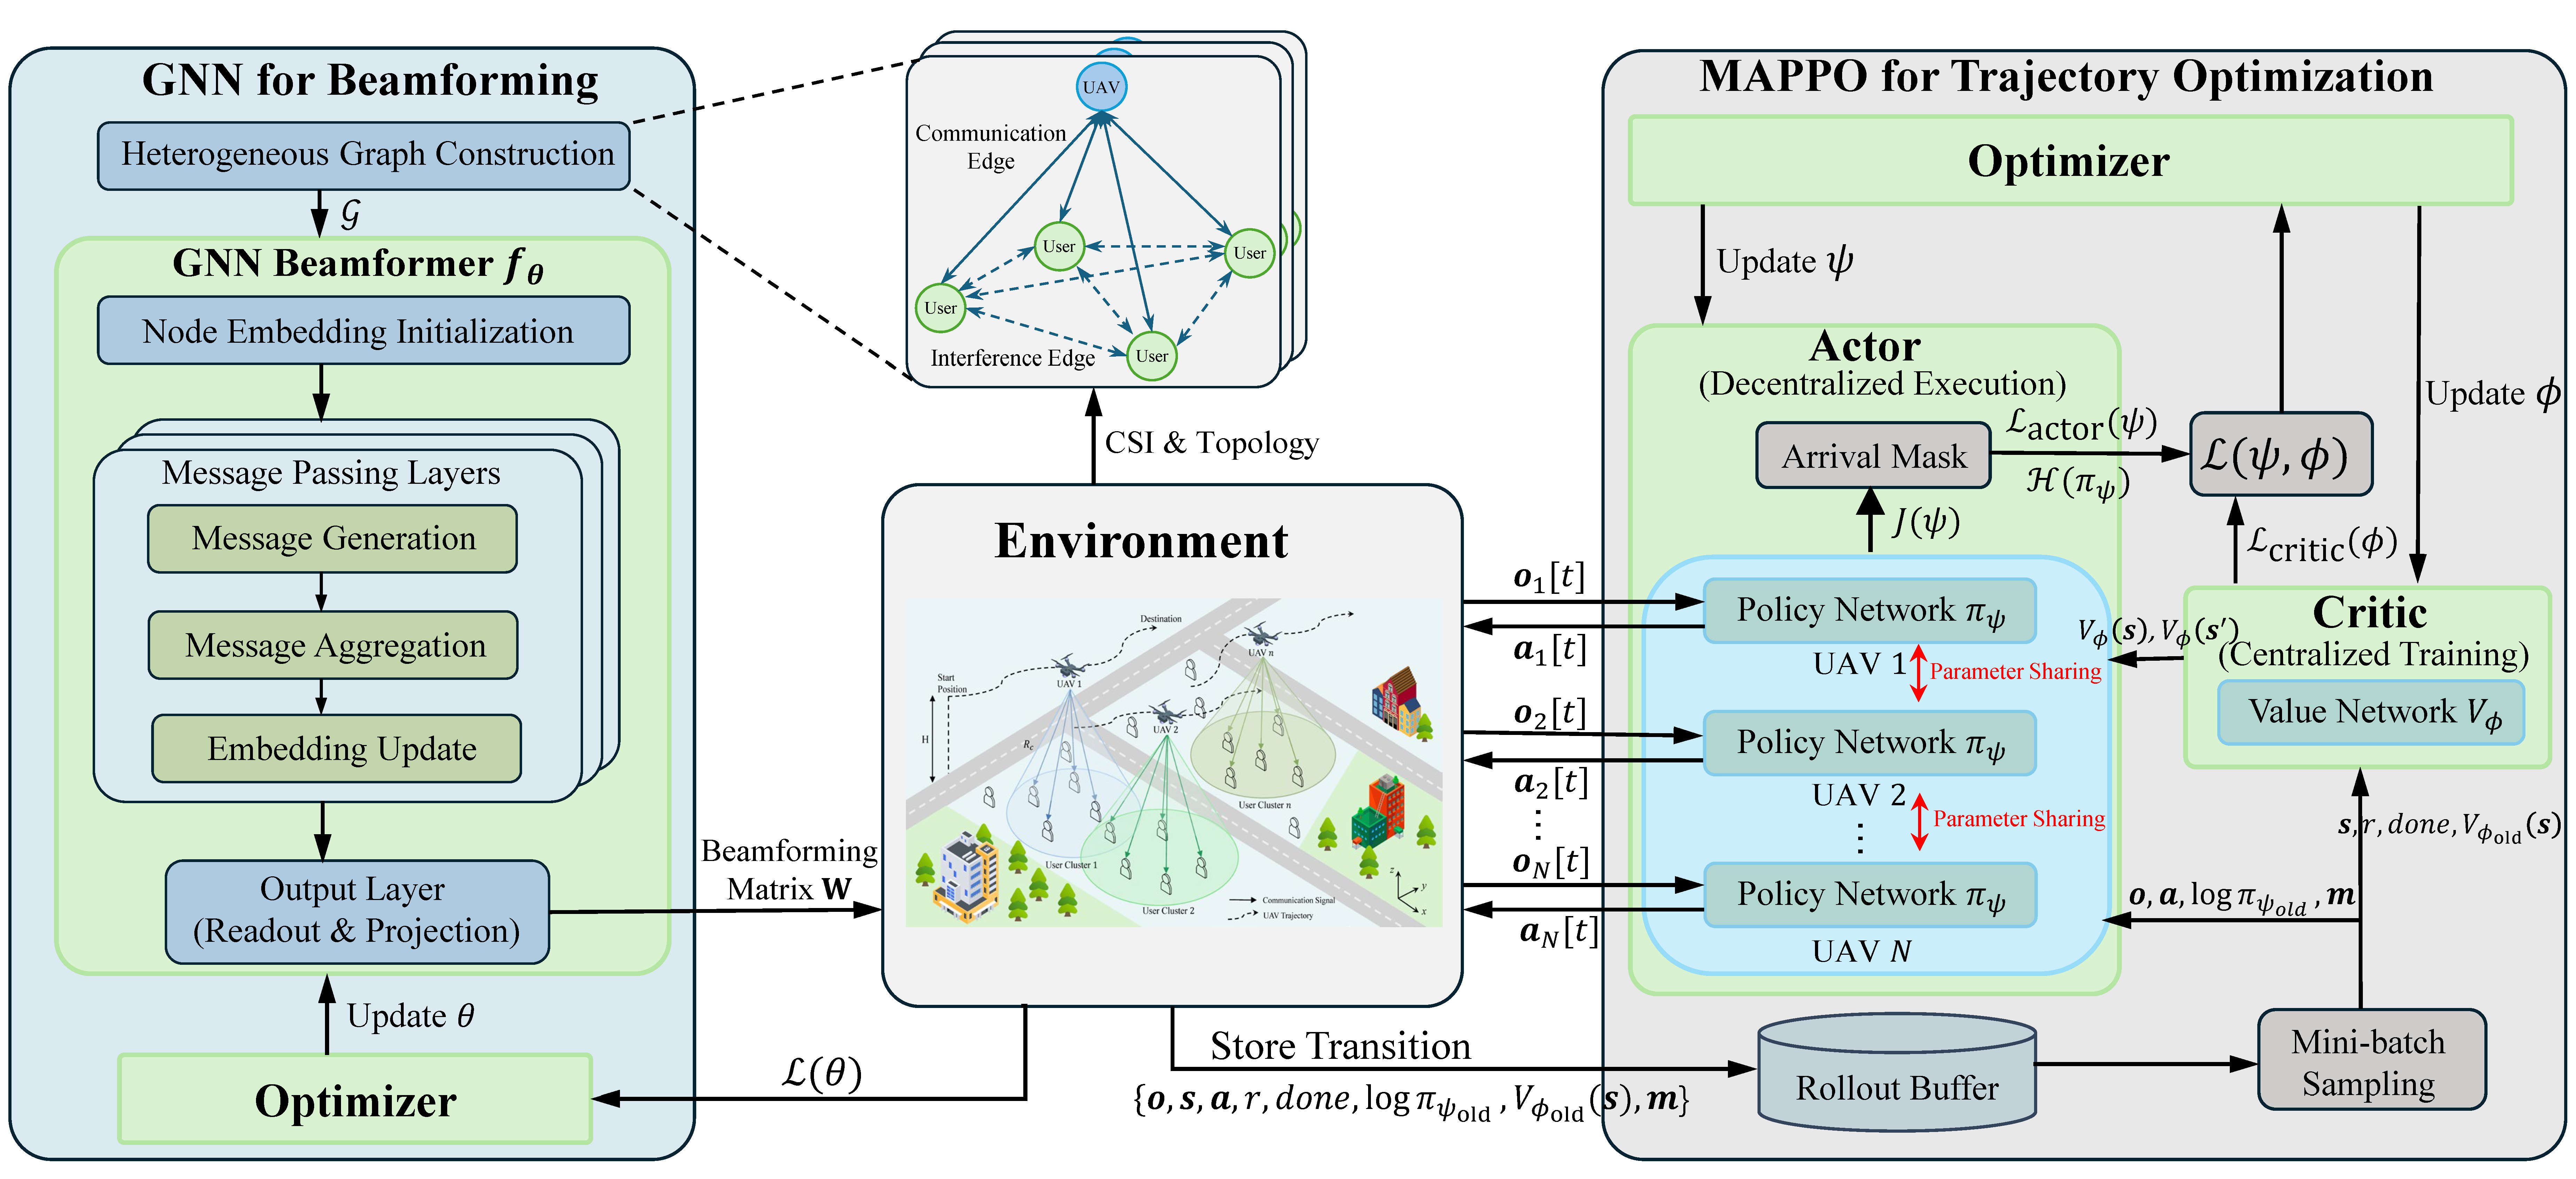
Description: This project develops a learning-based framework for multi-UAV downlink communications. It decouples short-term beamforming and long-term cooperative trajectory planning, combines topology-aware GNN beamforming with MAPPO-based path planning, and follows the centralized-training decentralized-execution paradigm.